FTC Robotics: Autonomous & Programming Lead
For three seasons, I was the autonomous and programming lead for my high school FTC robotics team. I wrote code to autonomously locate the robot using computer vision techniques and reference photos.
- When
- 2017 – 2020
- Status
- Completed
- Role
- Autonomous & programming lead
Overview
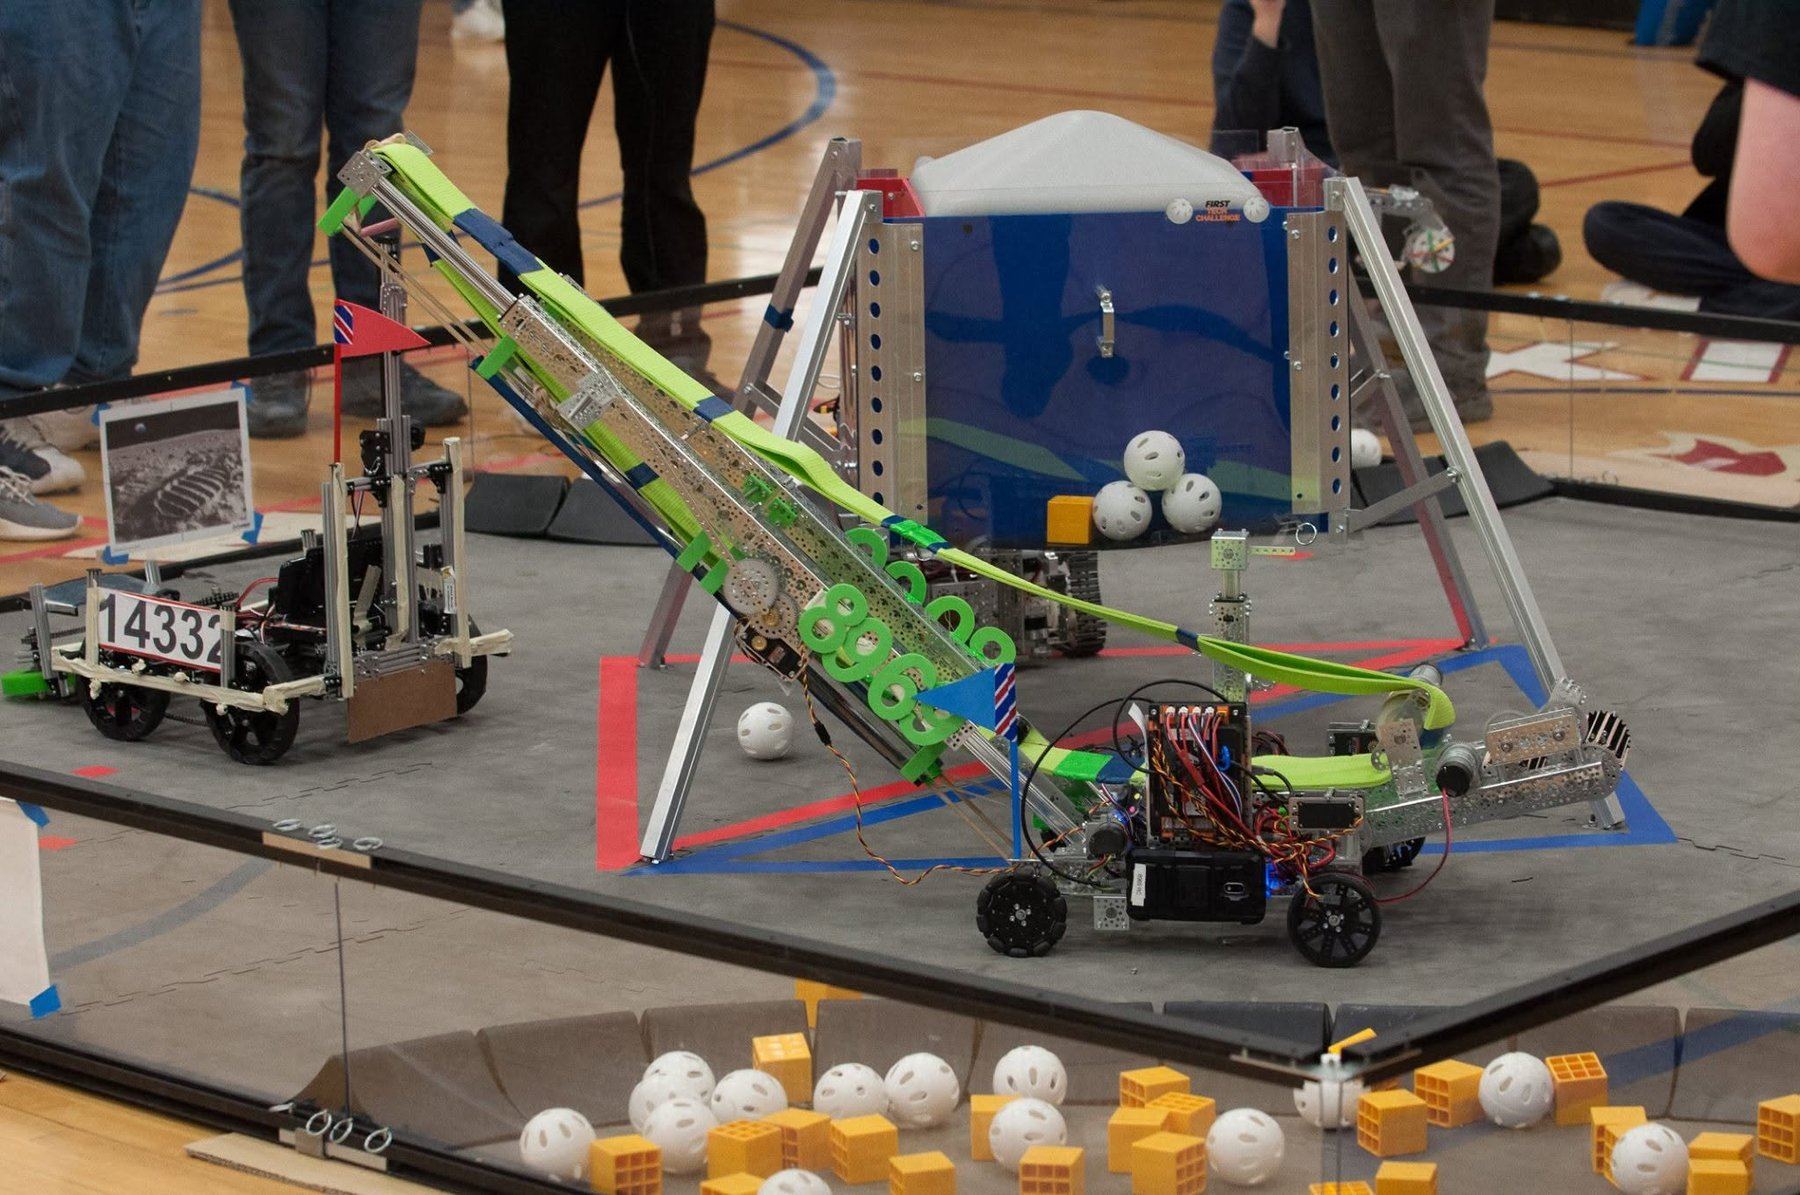
For three seasons, including Relic Recovery (2017–18) and Rover Ruckus (2018–19), I was the sole autonomous and programming lead for my high school’s FIRST Tech Challenge (FTC) team. I was responsible for all the code that would run on the rover, from the human interface to autonomous code that had to run tasks independent of a user.
The robot shown was an especially innovative design: though the robot had to fit in a cube to start, we designed a system in which the rover would expand and extend to set up a conveyor system to transport cubes and balls from a crater region into a central cache.
Vision navigation
The robot’s phone tracks image targets on the field with Vuforia. I derived a correction that factors the phone’s rotation out of the measured position to give more accurate results on positioning for the autonomous portion of the competition.
We qualified at the regional competition every year but never advanced past the state competition. However, nearly every year I competed, the winner of the competition in Colorado won nationals as well, so we had some skilled competitors!